OnRobot 3FG25 Finger Gripper

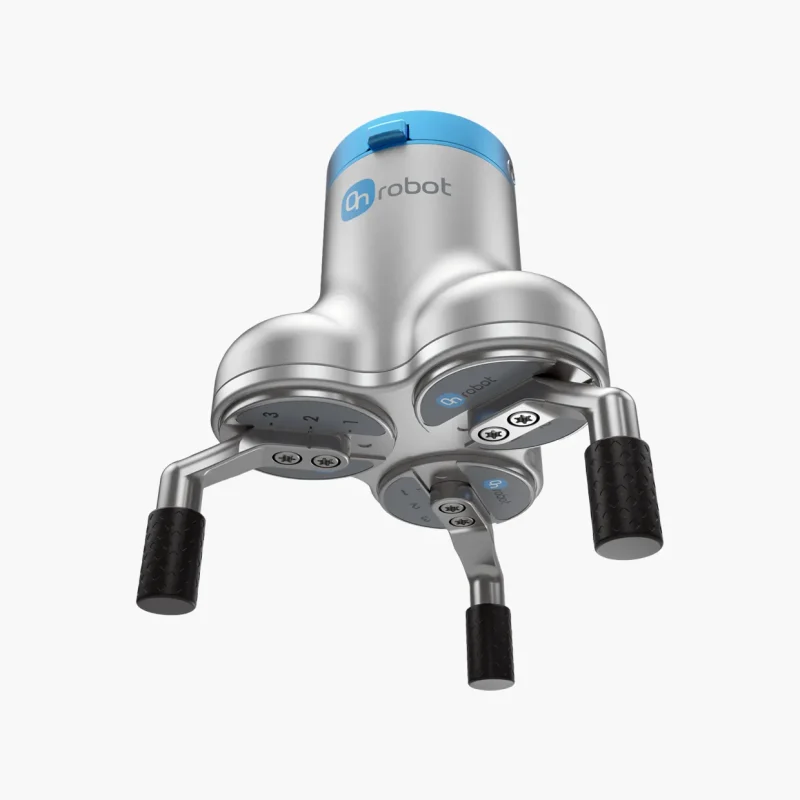
The OnRobot 3FG25 Finger Gripper is a heavy-duty electric 3-finger gripper designed for handling larger and heavier parts in demanding industrial applications.

With a payload of up to 25 kg, self-centering capability, and a rugged IP67-rated design, it is suitable for machine tending, material handling, and assembly involving large parts.

Share this product on social media:

Heavy-duty 3-finger gripper for heavy parts

The OnRobot 3FG25 Finger Gripper is the more powerful version in the 3-finger gripper family and is designed for applications where parts are heavier, larger, or more difficult to stabilize during gripping. With a capacity of up to 25 kg, the model is particularly suited for machine tending, handling, and assembly applications where force and stability are key criteria.

Self-centering for precise and repeatable positioning

Like the 3FG15, this model features a three-point centric grip, making it ideal for positioning parts in chucks, fixtures, or process stations. The difference is that this model is designed for heavier parts and more demanding conditions, where a smaller gripper would not provide sufficient force reserve.

Designed for harsh industrial environments

Its robust construction and IP67 rating make it ideal for machine shops and applications involving coolants, contaminants, or harsh operating conditions. In such environments, the 3FG25 is the perfect choice because it retains the advantages of an electric gripper without the fragility of an overly sensitive solution.

A complete solution, without complicated additional development

Delivered as a complete, integration-ready product, the gripper reduces implementation time and design effort. For companies that need a powerful gripper but do not want to invest in a more complex custom pneumatic solution, the 3FG25 is a highly efficient and easy-to-implement option.

Where it makes sense

  • machine tending involving heavy and bulky parts
  • material handling in challenging environments
  • assembly of large components
  • applications requiring self-centering and high lifting force
Industries

Industrial production

Model 3FG25
Device type 3-finger electric center gripper
Payload (friction grip) 15 kg (33.06 lb)
Payload (flexible gripping) 10 kg (22 lb)
Payload (form-fit clamping) 25 kg (55.1 lb)
External mounting diameter 18–155 mm
Internal mounting diameter 41–184 mm
Finger position resolution 0.1 mm
Diameter repeatability 0.1–0.2 mm
Motor torque on the finger platform 7.4 Nm
Grip strength (normal grip) 50–450 N
Grip strength (flexible grip) 50–300 N
Adjustable clamping force 1–100%
Clamping speed (diameter adjustment) 90 mm/s
Curing time 500 ms
Minimum change in diameter 3 mm
Power failure protection Yes
Engine Integrated electric BLDC motor
Protection rating IP67
Dimensions (L × W × Ø) 156 × 168 × 187 mm
Weight 1.6 kg
Power supply 20–25 V DC
Current consumption 50–1,500 mA
Operating temperature 5–50 °C
Storage temperature 0–60 °C
Operating humidity 0–95% (non-condensing)
Warranty 3 years or 3,000,000 cycles
File name File size File type
Technical Specifications for the OnRobot 3FG25 Finger Gripper
.pdf, 2 MB
2 MB PDF

Talk to a specialist

Te ajutăm să identifici soluția potrivită, adaptată procesului tău de producție și obiectivelor tale.

Request a quote

Pentru o ofertă personalizată, completează formularul sau folosește opțiunea de lista de ofertare.

Need help?

Echipa noastră îți oferă sprijin și răspunde rapid la întrebări sau solicitări. Solicită suport tehnic →

Schedule an appointment

If you'd prefer a personal consultation, schedule an appointment, and our team will give you a one-on-one presentation.

By filling out this form, you agree to the Privacy Policy.

The information you provide will be used solely to respond to your request and to contact you regarding the products or solutions that interest you. The information you provide will be treated confidentially and will not be used for unsolicited communications.

OnRobot 3FG25 Finger Gripper

Add to quote list